B
XLeRobot Mobile Dual-Arm (Basic)
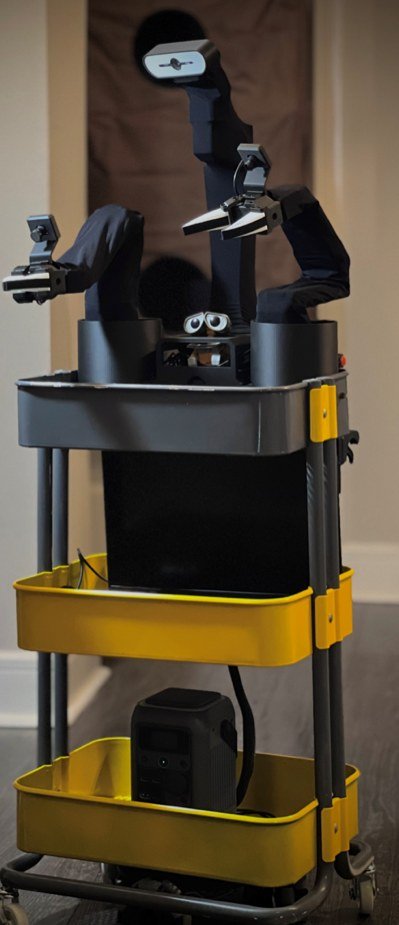
Two SO-101 arms on an omni-wheel base with a head camera. Mobile manipulation for the price of a laptop.
USD 1,099Pre-order · ships 30 days after order
Basic configuration as defined by the upstream project: no Raspberry Pi, no cart, no power bank. Those are cheaper to buy locally than to ship.
Reserve a build slot
No payment now. Fully refundable before shipment.
Who it is for
Labs moving from tabletop to mobile manipulation; household-robot research; VLA data collection.
What is in the box
- 2× SO-101 follower arms + 2× leader arms, assembled
- Omni-wheel base, assembled
- Head camera on 2-axis gimbal
- 17× Feetech STS3215 12 V servos, IDs pre-set
- 2× USB bus-servo adapters, cabling
- Both arms and base calibrated; quick-start sheet
Specifications
| Arms | 2× (5 DOF + gripper), reach approx. 440 mm each |
|---|---|
| Base | 3-wheel omnidirectional |
| Head | 2-axis, USB camera |
| Servos | 17× Feetech STS3215 12 V |
| Compute | laptop-driven (Raspberry Pi not included) |
| Power | 2× 60 W USB-C power bank (not included; recommended model listed in the manual) |
| Software | LeRobot + XLeRobot repo (Apache-2.0) |
| Not included | IKEA RÅSKOG cart (buy locally, ~$30) |
Specifications marked "to be measured" are filled in after our first units are built; values marked "community" or "upstream" come from the project documentation.
Open-source design
Vector-Wangel/XLeRobot · Apache-2.0
Photo credit: Photo: XLeRobot project (Apache-2.0). Will be replaced by photos of our own units.